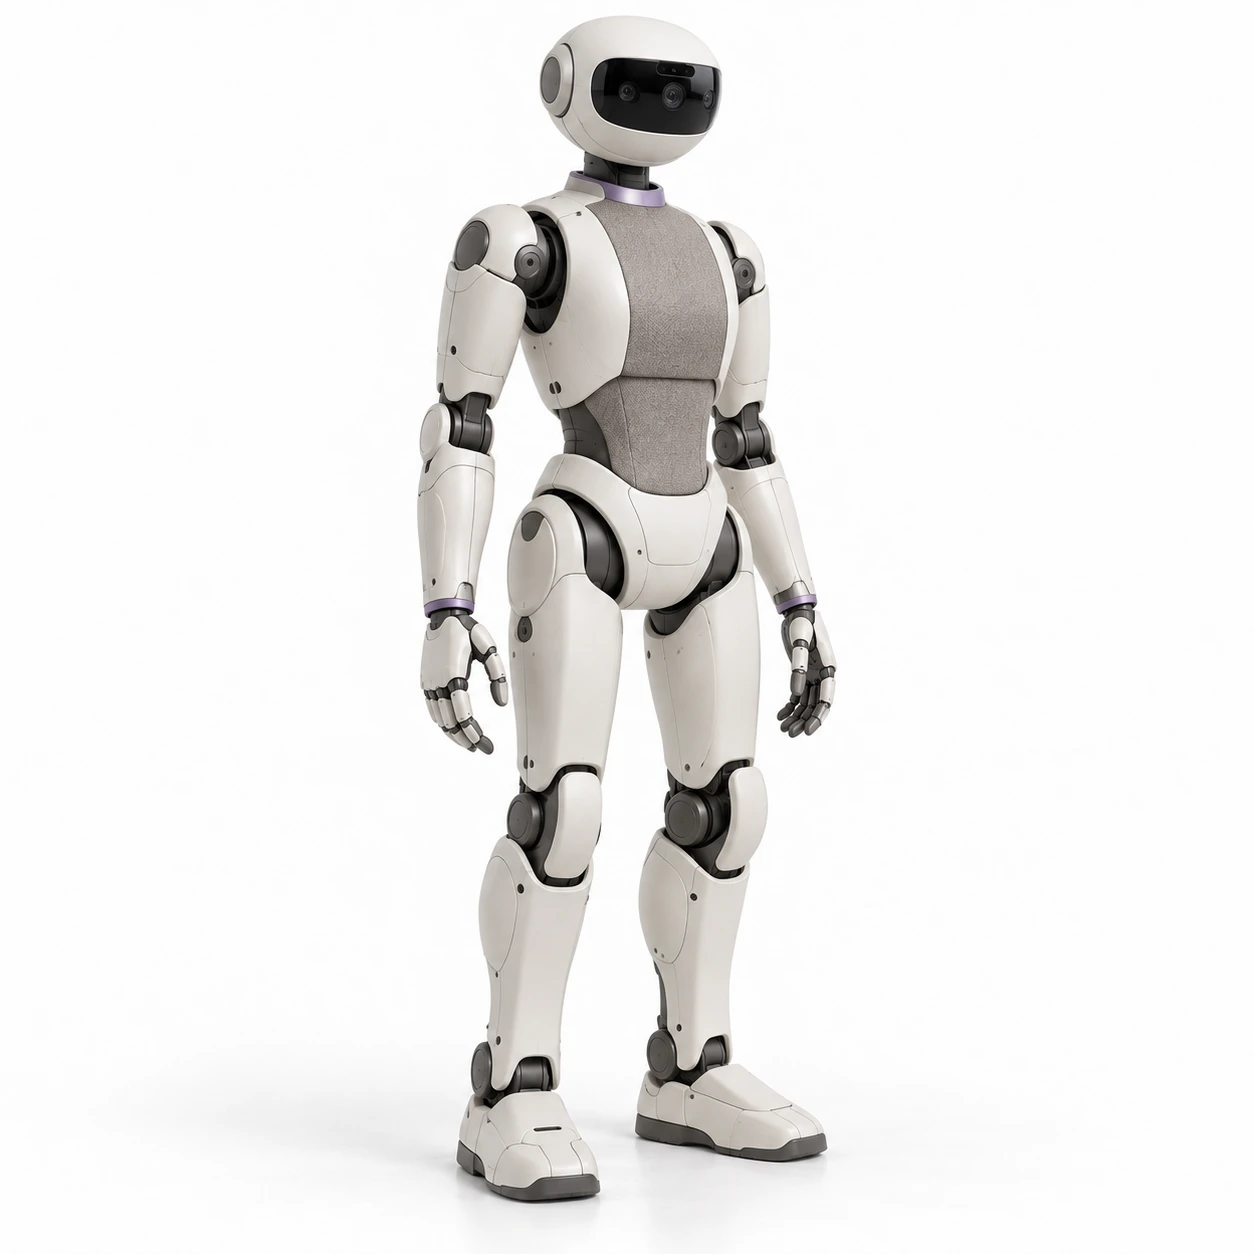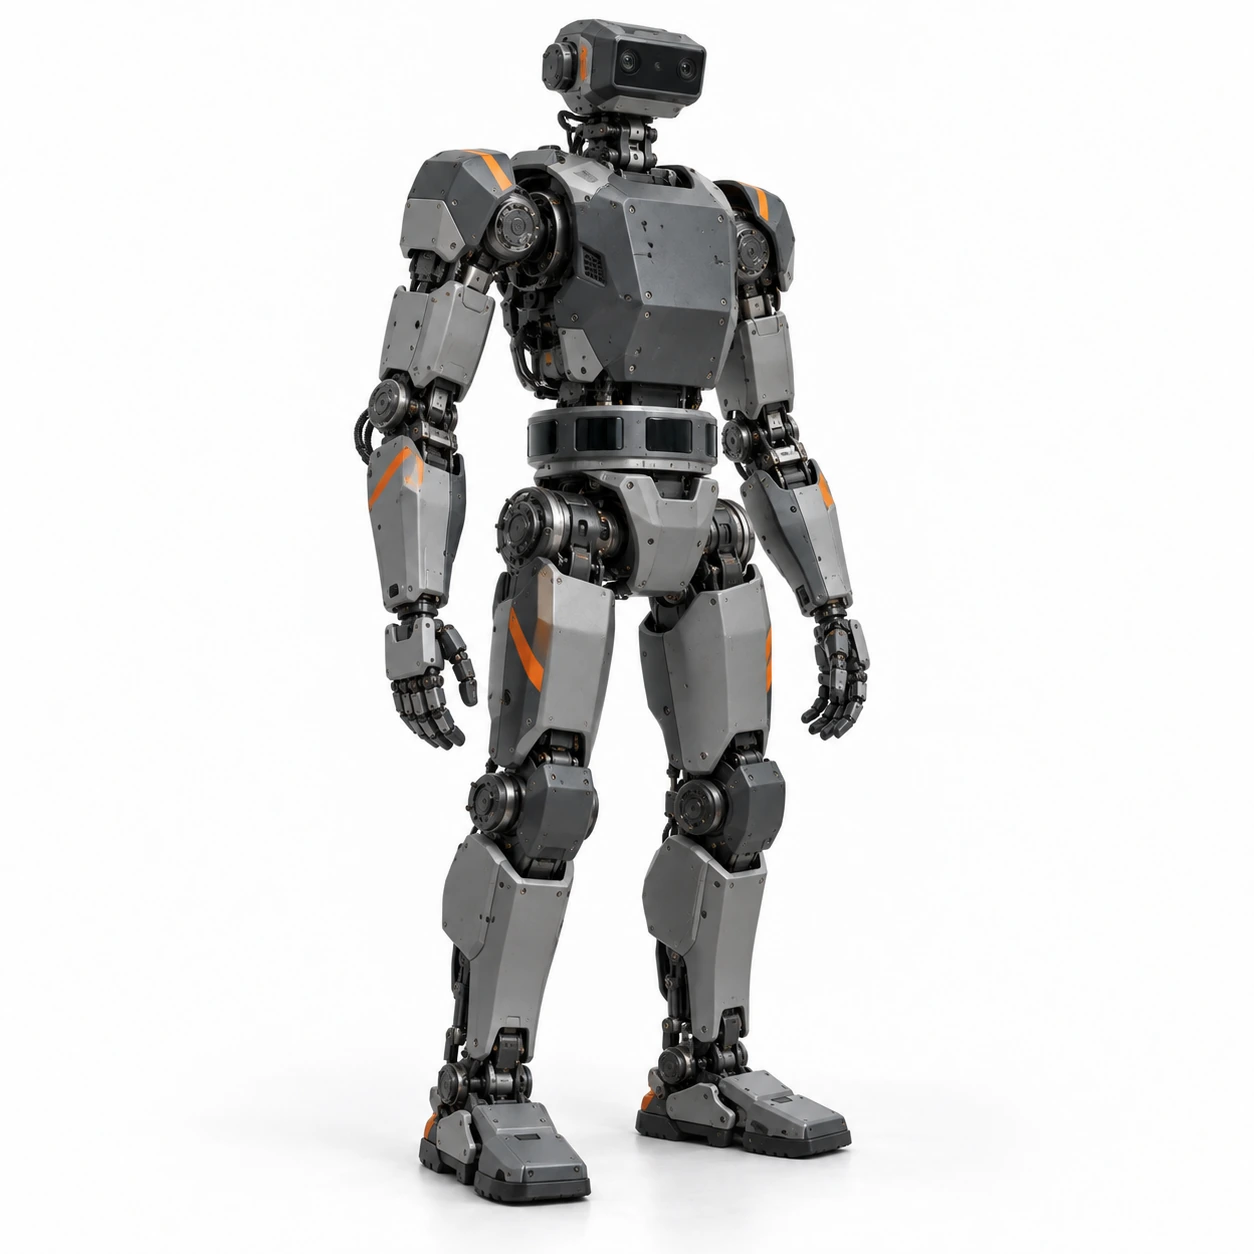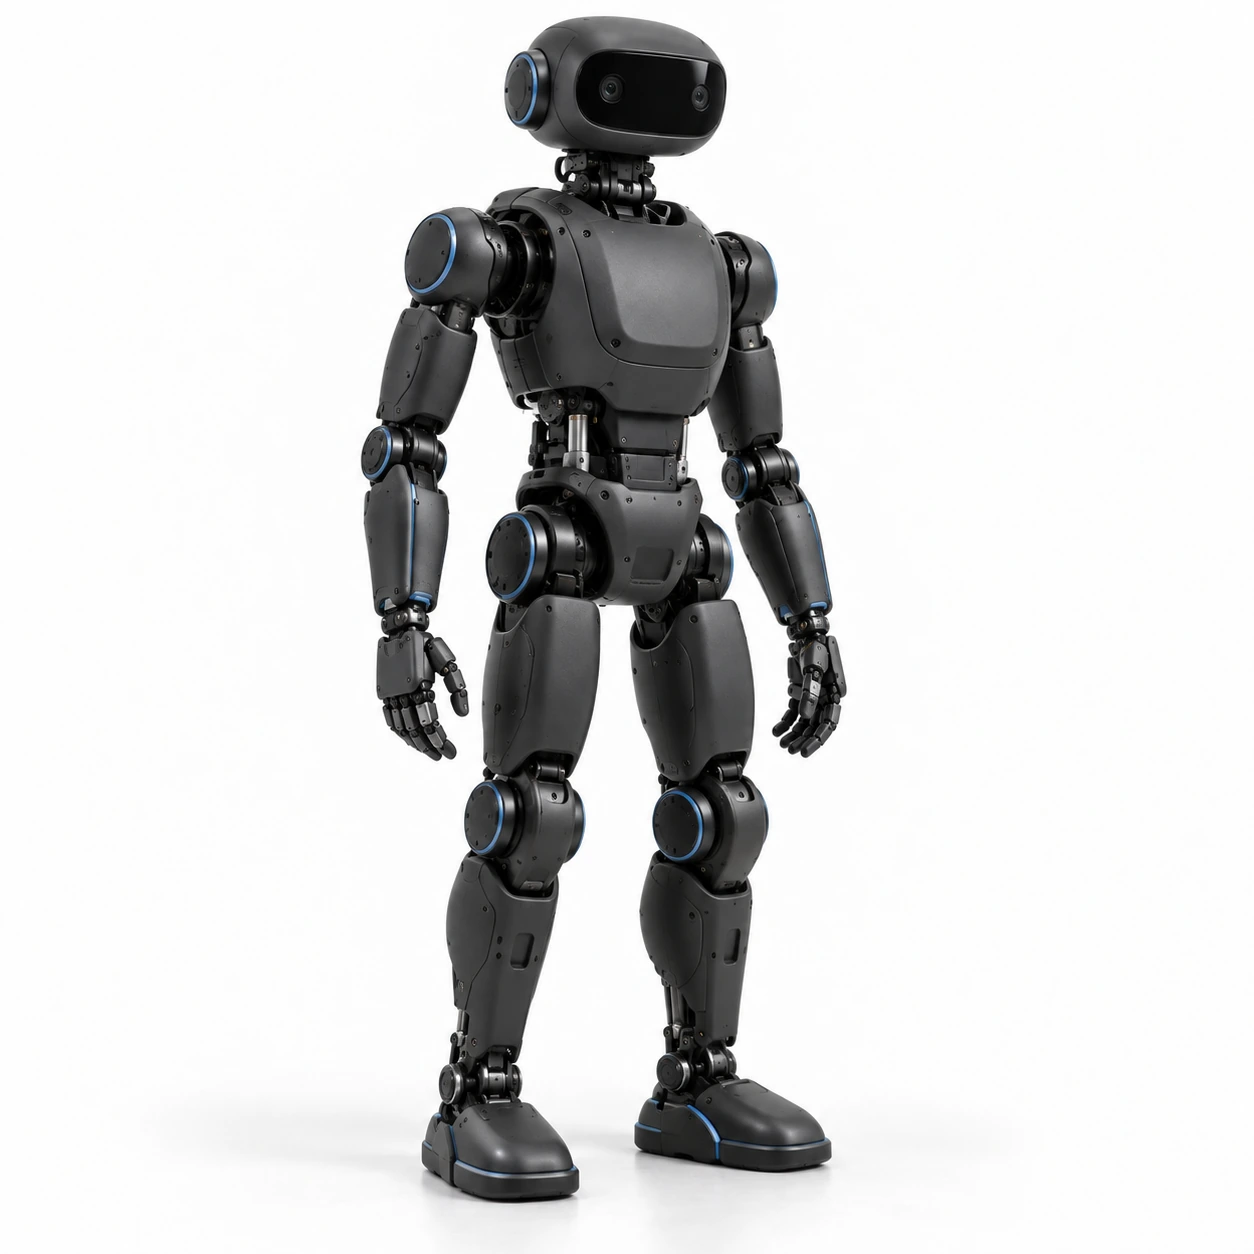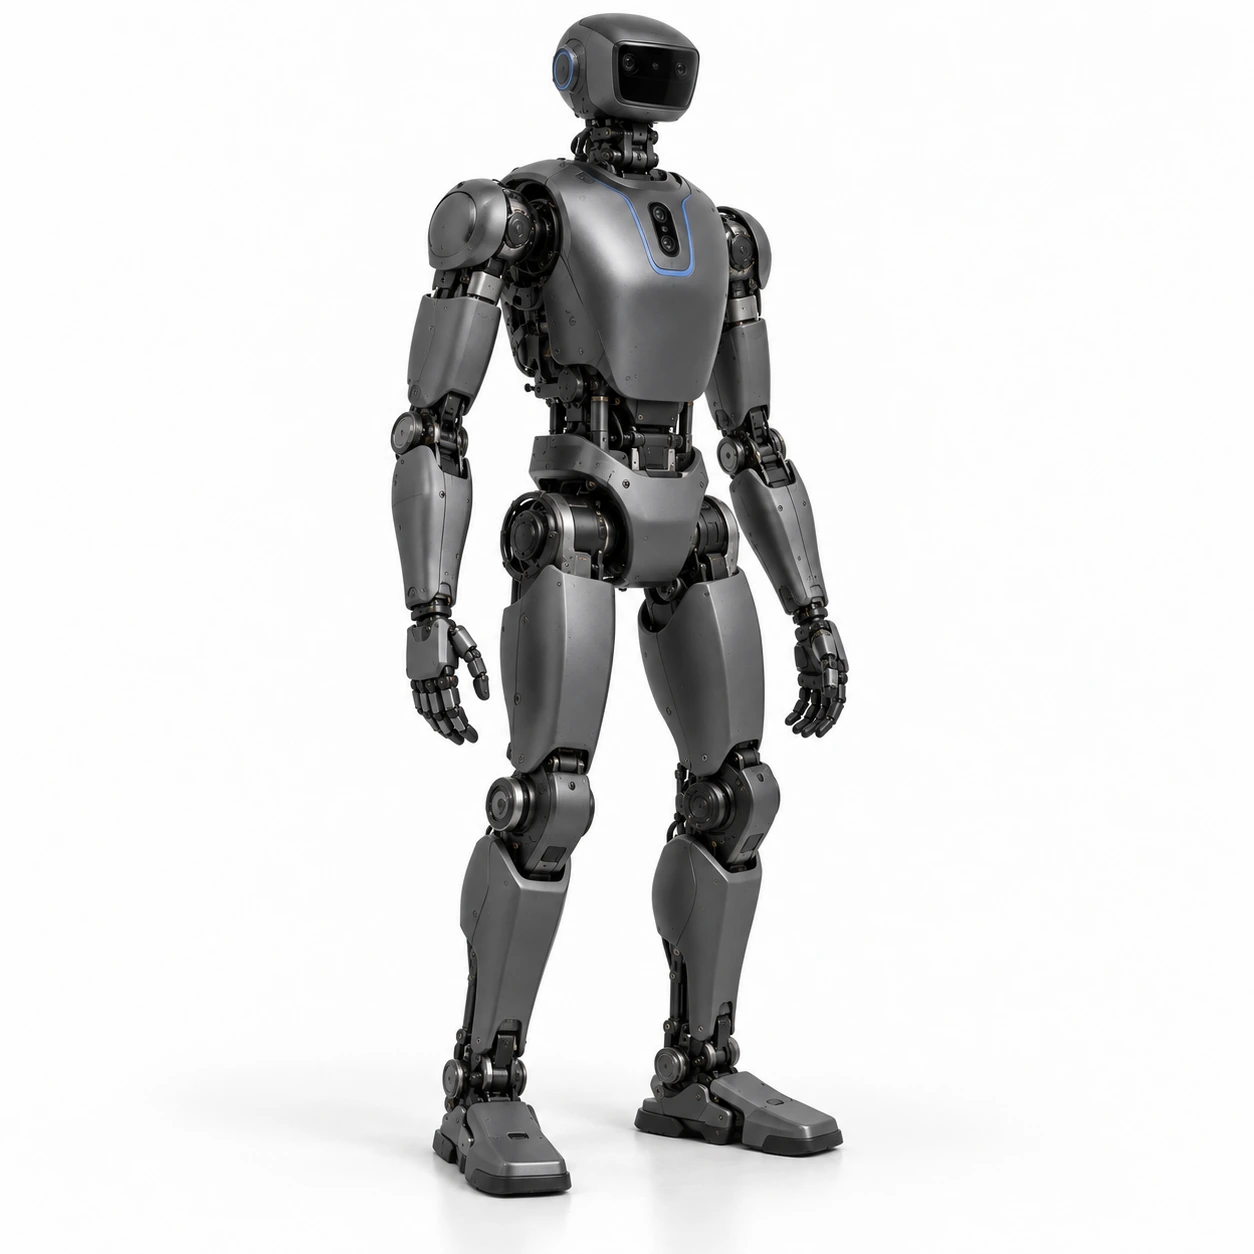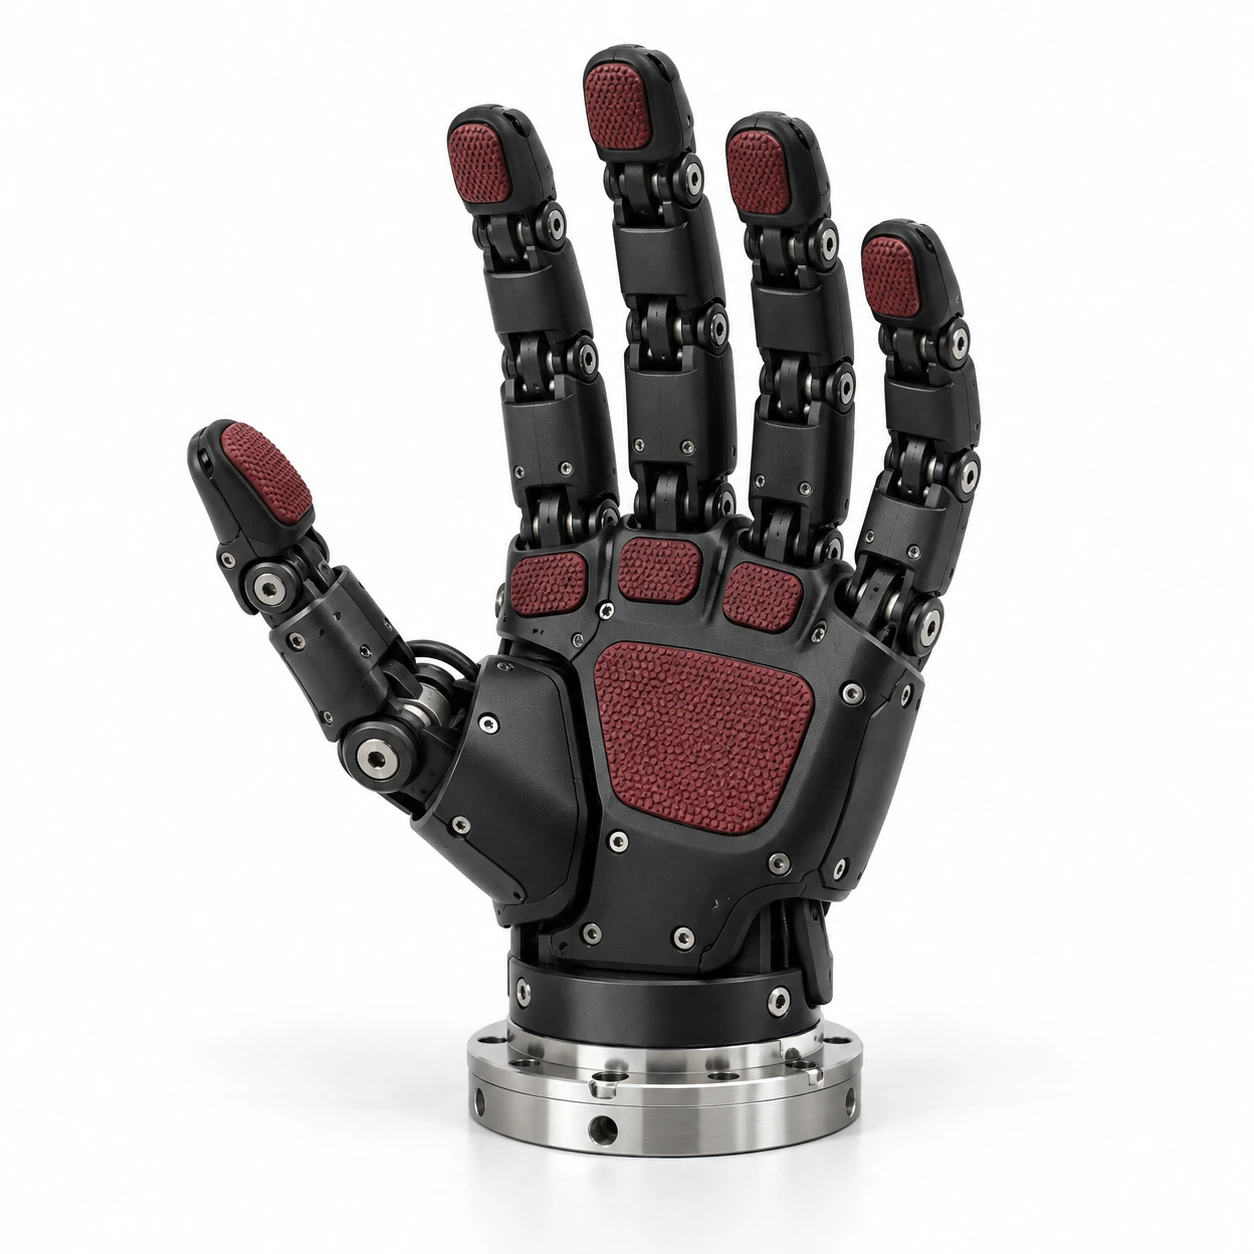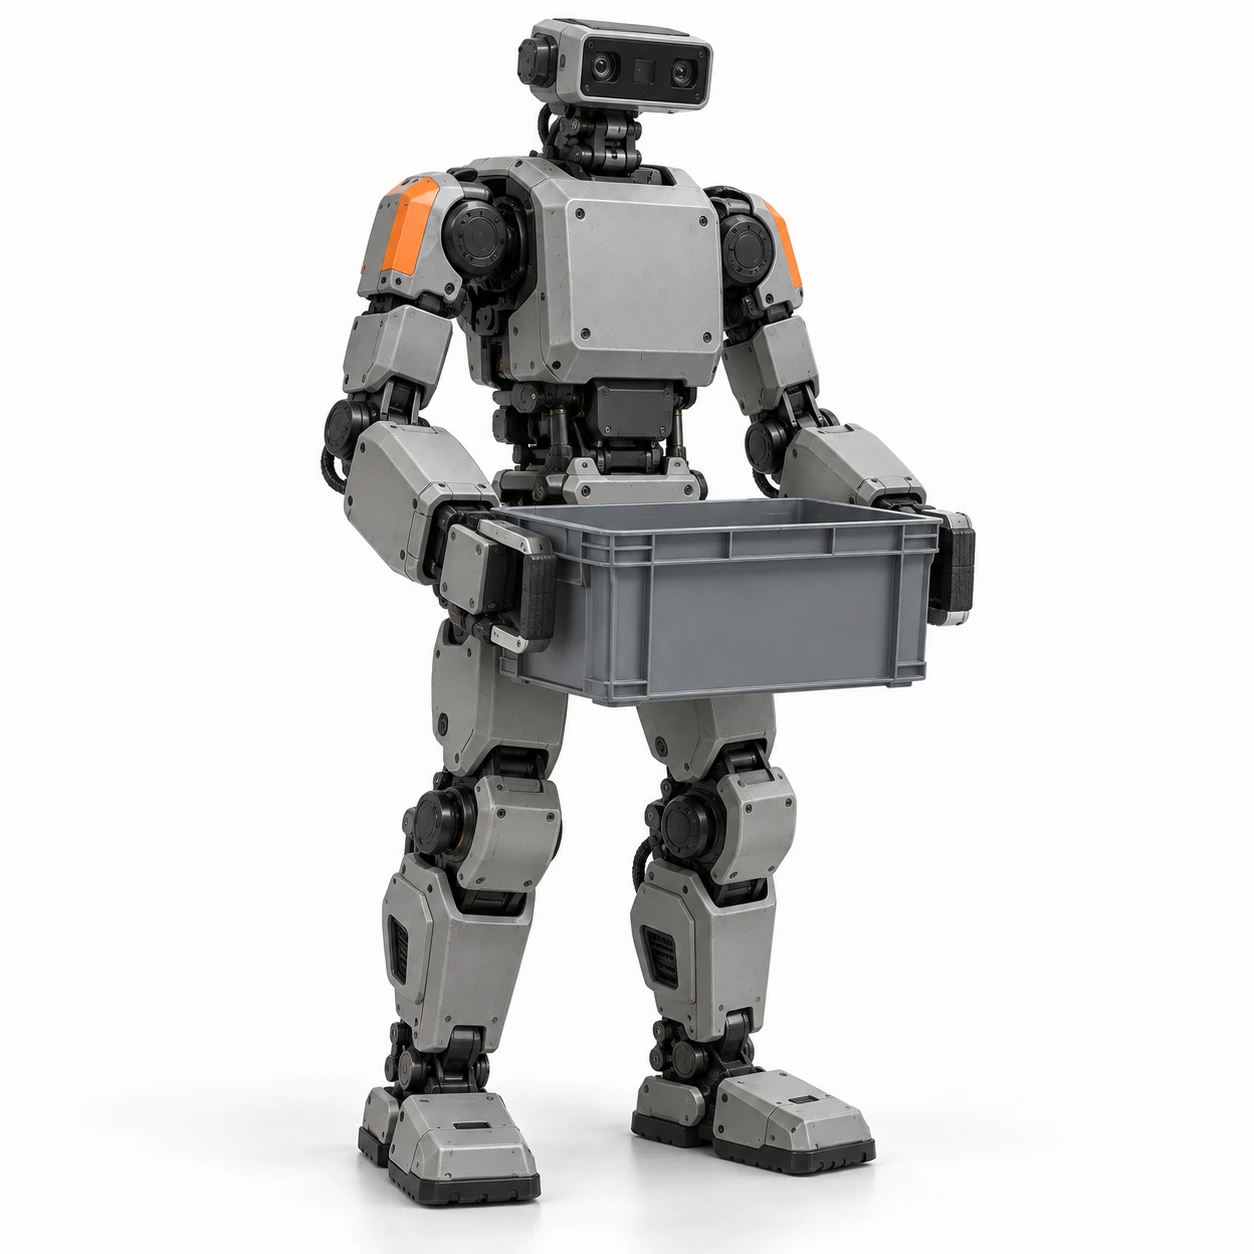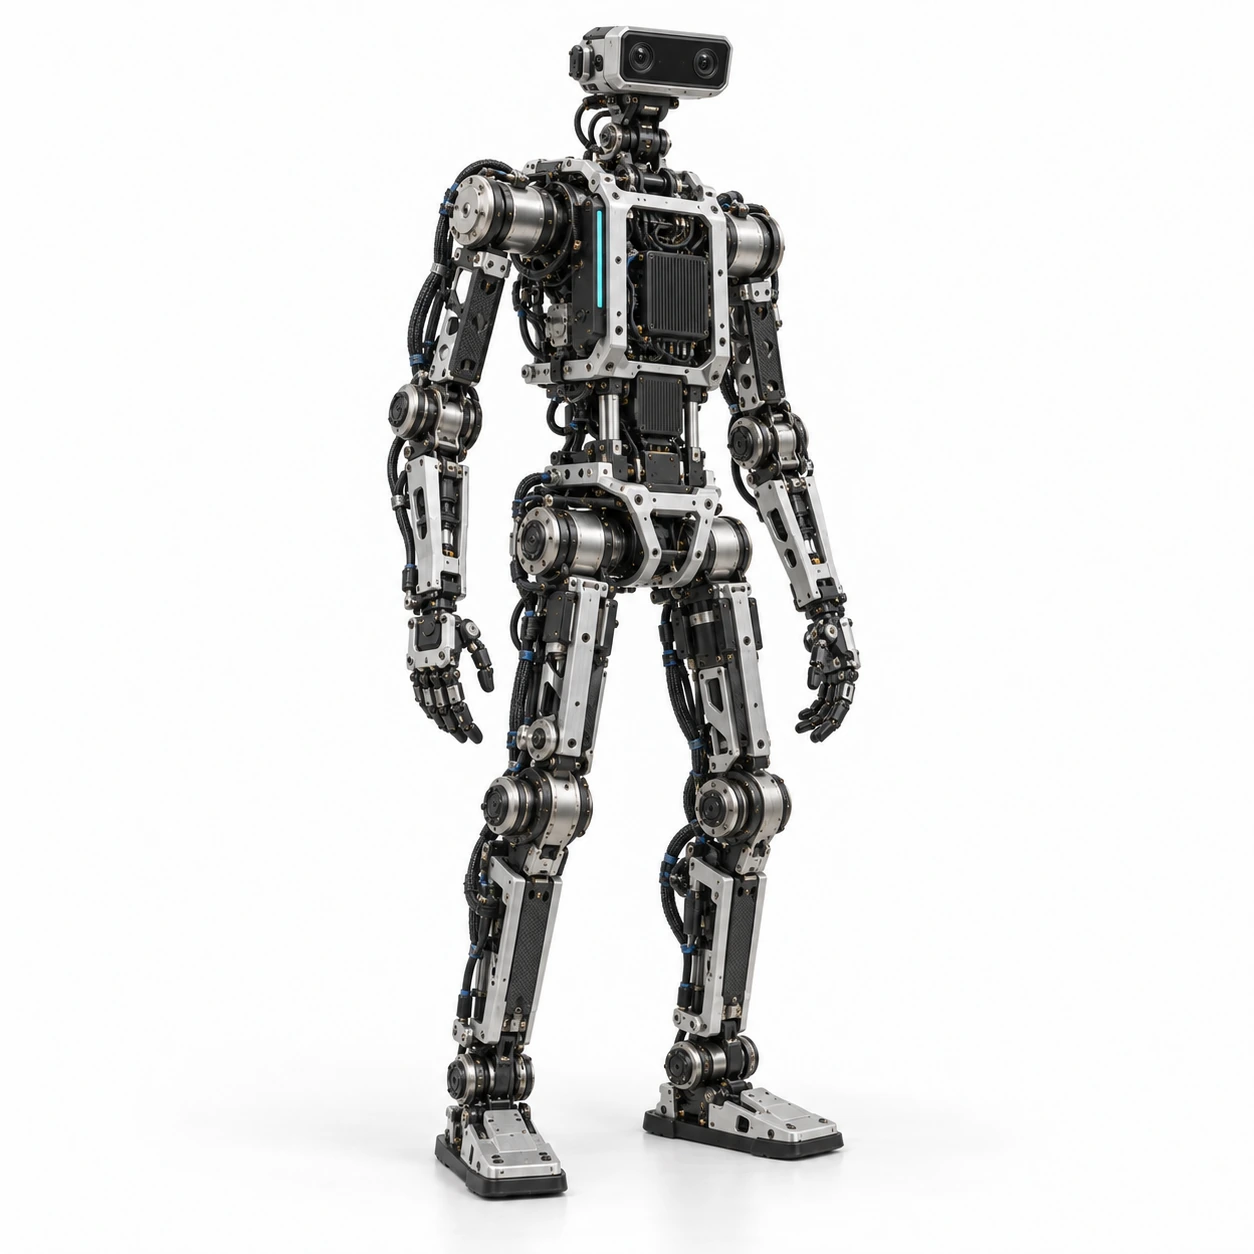
Lumen Robotics Stride S3 Research Humanoid, 172cm Torque-Controlled Bipedal Platform, 60 DOF, 400Hz Whole-Body Control, Open State Access, MuJoCo & Isaac Sim
2K+ bought in past month
About this item
- TRUE RESEARCH ACCESS: unlocked firmware, raw 1 kHz joint telemetry and EtherCAT external control let your lab run its own whole-body controllers.
- 60 TRANSPARENT-TORQUE JOINTS: low-friction quasi-direct-drive actuators expose accurate torque estimates essential for learned locomotion and contact-rich manipulation research.
- SIM-TO-REAL, MINIMIZED: system-identified MuJoCo and Isaac Sim models with per-unit calibration reports shrink the reality gap dramatically.
- 400 HZ WHOLE-BODY CONTROL: hard real-time loop with deterministic latency supports aggressive dynamic behaviors, from running gaits to recovery stepping.
- LAB-READY PACKAGE: gantry mount, e-stop pendant, spare covers and priority engineering support are included with every hand-assembled unit.
| Brand | Lumen Robotics |
|---|---|
| Height | 172 cm |
| Weight | 64 kg |
| Battery | 1.4 kWh swap pack, approx. 2.5 h dynamic use |
| Included | Gantry mount, e-stop pendant, calibration report |
| Interfaces | EtherCAT, 10GbE, USB-C debug |
| Model Name | Stride S3 |
| Control Loop | 400 Hz whole-body, 1 kHz joint telemetry |
FREE Returns — 30-day refund or replacement, no questions asked. Ships in 3-5 business days to your address or pickup point.
FREE delivery Wednesday, November 4
Or fastest delivery Tomorrow, November 2. Order within 5 hrs
In Stock
Product information
| Brand | Lumen Robotics |
|---|---|
| Height | 172 cm |
| Weight | 64 kg |
| Battery | 1.4 kWh swap pack, approx. 2.5 h dynamic use |
| Included | Gantry mount, e-stop pendant, calibration report |
| Interfaces | EtherCAT, 10GbE, USB-C debug |
|---|---|
| Model Name | Stride S3 |
| Control Loop | 400 Hz whole-body, 1 kHz joint telemetry |
| Peak Joint Torque | 360 Nm (hip pitch) |
| Degrees of Freedom | 60 |
Product description
The Stride S3 is Lumen Robotics' no-compromise research platform, built for labs pushing the frontier of locomotion, whole-body control and learned policies. Sixty transparent-torque joints expose raw current, position and temperature telemetry at 1 kHz, with a hard real-time 400 Hz whole-body control loop that accepts external controllers over EtherCAT. Unlike closed commercial platforms, the S3 ships with full state access and no locked firmware layers. Validated MuJoCo and Isaac Sim models with system-identified parameters mean policies transfer from simulation with minimal reality gap, and the included gantry mount and e-stop pendant support safe early experiments. Each S3 is hand-assembled and factory-characterized; a signed calibration report documenting joint friction, backlash and inertial parameters accompanies every serial number. Availability is limited to small batches.